
Book Details
Delivery Location
Delivery fee: Select location
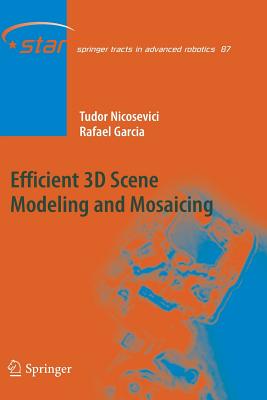
This book proposes a complete pipeline for monocular (single camera) based 3D mapping of terrestrial and underwater environments. The aim is to provide a solution to large-scale scene modeling that is both accurate and efficient. To this end, we have developed a novel Structure from Motion algorithm that increases mapping accuracy by registering camera views directly with the maps. The camera registration uses a dual approach that adapts to the type of environment being mapped.
In order to further increase the accuracy of the resulting maps, a new method is presented, allowing detection of images corresponding to the same scene region (crossovers). Crossovers then used in conjunction with global alignment methods in order to highly reduce estimation errors, especially when mapping large areas. Our method is based on Visual Bag of Words paradigm (BoW), offering a more efficient and simpler solution by eliminating the training stage, generally required by state of the art BoW algorithms.
Also, towards developing methods for efficient mapping of large areas (especially with costs related to map storage, transmission and rendering in mind), an online 3D model simplification algorithm is proposed. This new algorithm presents the advantage of selecting only those vertices that are geometrically representative for the scene.
Get Efficient 3D Scene Modeling and Mosaicing by Rafael Garcia, Tudor Nicosevici at the best price and quality guaranteed only at Werezi Africa's largest book ecommerce store. The book was published by Springer-Verlag Berlin and Heidelberg GmbH & Co. KG and it has 161 pages.
Customers Who Bought This Also Bought
Artificial Intelligence on Dark Matter and Dark Energy
KSh 10,100.00
Intelligent Systems
KSh 30,950.00

Buhnentechnik
KSh 16,450.00

Introduction to Data Science
KSh 9,900.00

Computer Vision and SLDV for Structural Dynamics, 2026
KSh 19,800.00

Artificial Intelligence and Sustainable Management
KSh 22,500.00

Mathematical Algorithms for Educational Data Classification
KSh 18,700.00

Digitalization of Mechanical Systems
KSh 33,850.00

Artificial Intelligence and Sustainable Management
KSh 9,900.00

Bridging Physics and AI
KSh 13,300.00

Bridging Physics and AI
KSh 33,850.00

Modern Missile Guidance
KSh 33,850.00
More in This Genre
Artificial Intelligence on Dark Matter and Dark Energy
KSh 10,100.00
Intelligent Systems
KSh 30,950.00
Buhnentechnik
KSh 16,450.00
Introduction to Data Science
KSh 9,900.00
Computer Vision and SLDV for Structural Dynamics, 2026
KSh 19,800.00
Artificial Intelligence and Sustainable Management
KSh 22,500.00
