
Book Details
Format
Paperback / softback
Book Series
Communications and Control Engineering
ISBN-10
1447139097
ISBN-13
9781447139096
Edition
Third Edition 1995
Publisher
Springer London Ltd
Imprint
Springer London Ltd
Country of Manufacture
GB
Country of Publication
GB
Publication Date
Oct 3rd, 2013
Print length
549 Pages
Weight
850 grams
Dimensions
15.70 x 23.40 x 3.60 cms
KSh 36,000.00
Currently unavailable
0 in stock
Delivery Location
Delivery fee: Select location
Secure
Quality
Fast
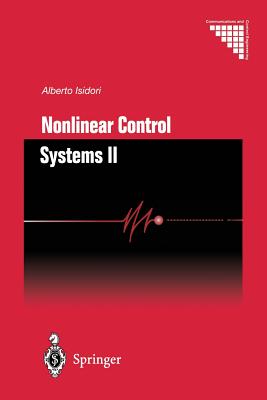
The purpose of this book is to present a self-contained description of the fun damentals of the theory of nonlinear control systems, with special emphasis on the differential geometric approach.
The purpose of this book is to present a self-contained description of the fun damentals of the theory of nonlinear control systems, with special emphasis on the differential geometric approach. The book is intended as a graduate text as weil as a reference to scientists and engineers involved in the analysis and design of feedback systems. The first version of this book was written in 1983, while I was teach ing at the Department of Systems Science and Mathematics at Washington University in St. Louis. This new edition integrates my subsequent teaching experience gained at the University of Illinois in Urbana-Champaign in 1987, at the Carl-Cranz Gesellschaft in Oberpfaffenhofen in 1987, at the University of California in Berkeley in 1988. In addition to a major rearrangement of the last two Chapters of the first version, this new edition incorporates two additional Chapters at a more elementary level and an exposition of some relevant research findings which have occurred since 1985.
Get Nonlinear Control Systems by Alberto Isidori at the best price and quality guaranteed only at Werezi Africa's largest book ecommerce store. The book was published by Springer London Ltd and it has 549 pages.
Customers Who Bought This Also Bought
Thinking in Systems
KSh 3,050.00
For Everyone Bible Study Guide: Luke
KSh 1,250.00
The Laws of Thought
KSh 2,000.00
Laws of Thought
KSh 3,050.00
Laws of Thought
KSh 4,500.00
Frankenstein and STEAM – Essays for Charles E. Robinson
KSh 22,300.00

Algorithms in Advanced Artificial Intelligence
KSh 30,950.00

Algorithms in Advanced Artificial Intelligence
KSh 9,350.00
Linear Systems Theory
KSh 37,800.00
Fractals and Chaos
KSh 28,450.00
Theories and Models of Urbanization
KSh 26,800.00
Machine Intelligence and Data Analytics for Sustainable Future Smart Cities
KSh 27,000.00