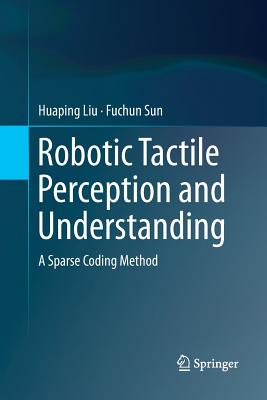
Robotic Tactile Perception and Understanding : A Sparse Coding Method
Softcover reprint of the original 1st ed. 2018
Book Details
Format
Paperback / softback
ISBN-10
9811338736
ISBN-13
9789811338731
Edition
Softcover reprint of the original 1st ed. 2018
Publisher
Springer Verlag, Singapore
Imprint
Springer Verlag, Singapore
Country of Manufacture
GB
Country of Publication
GB
Publication Date
Dec 29th, 2018
Print length
207 Pages
Product Classification:
Artificial intelligenceArtificial intelligence (AI)Pattern recognitionComputer vision
KSh 19,800.00
Currently unavailable
0 in stock
Delivery Location
Delivery fee: Select location
Secure
Quality
Fast
This book introduces the challenges of robotic tactile perception and task understanding, and describes an advanced approach based on machine learning and sparse coding techniques.
This book introduces the challenges of robotic tactile perception and task understanding, and describes an advanced approach based on machine learning and sparse coding techniques. Further, a set of structured sparse coding models is developed to address the issues of dynamic tactile sensing. The book then proves that the proposed framework is effective in solving the problems of multi-finger tactile object recognition, multi-label tactile adjective recognition and multi-category material analysis, which are all challenging practical problems in the fields of robotics and automation. The proposed sparse coding model can be used to tackle the challenging visual-tactile fusion recognition problem, and the book develops a series of efficient optimization algorithms to implement the model. It is suitable as a reference book for graduate students with a basic knowledge of machine learning as well as professional researchers interested in robotic tactile perception and understanding, andmachine learning.
Get Robotic Tactile Perception and Understanding by Fuchun Sun, Huaping Liu at the best price and quality guaranteed only at Werezi Africa's largest book ecommerce store. The book was published by Springer Verlag, Singapore and it has 207 pages.
Customers Who Bought This Also Bought
Magnifica Humanitas
KSh 1,500.00

Nexus
KSh 2,350.00
The Thinking Machine
KSh 2,350.00
The Reverse Centaur's Guide to Life After AI
KSh 3,050.00

The MANIAC
KSh 2,000.00
Thinking With Machines: The Brave New World of AI
KSh 4,300.00
Prediction Machines
KSh 3,950.00
Confident AI
KSh 3,050.00
Responsible AI
KSh 6,400.00
Empire of AI
KSh 4,500.00
The MANIAC
KSh 2,700.00

Data Management, Analytics and Innovation
KSh 32,400.00
More by Fuchun Sun, Huaping Liu
Wearable Technology for Robotic Manipulation and Learning
KSh 23,400.00

Multi-sensor Fusion for Autonomous Driving
KSh 19,800.00

Autonomous Embodied AI
KSh 28,800.00

Visuo-Tactile Sensor in Robotics
KSh 28,800.00
Wearable Technology for Robotic Manipulation and Learning
KSh 23,400.00
Problem–Based Learning in Communication Systems Using MATLAB and Simulink
KSh 20,500.00

Embodied Multi-Agent Systems
KSh 28,800.00

Analysis and Design of Networked Control Systems under Attacks
KSh 9,000.00

Analysis and Design of Networked Control Systems under Attacks
KSh 18,700.00

Multi-sensor Fusion for Autonomous Driving
KSh 25,200.00