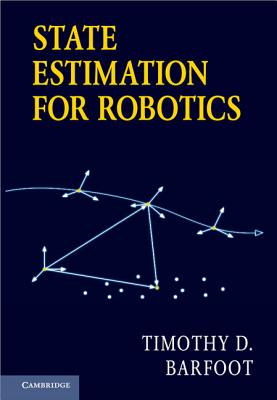
Book Details
Format
Hardback
ISBN-10
1009299891
ISBN-13
9781009299893
Edition
2 Revised edition
Publisher
Cambridge University Press
Imprint
Cambridge University Press
Country of Manufacture
GB
Country of Publication
GB
Publication Date
Feb 1st, 2024
Print length
530 Pages
Weight
1,170 grams
Dimensions
18.50 x 26.30 x 3.60 cms
Product Classification:
Cybernetics & systems theoryCybernetics and systems theoryStochasticsRobotics
KSh 13,800.00
Currently unavailable
0 in stock
Delivery Location
Delivery fee: Select location
Secure
Quality
Fast
This book is intended for students and practitioners of robotics working with noisy sensor data to estimate state variables. New edition highlights include a new chapter on variational inference and new sections on adaptive covariance estimation and on inertial navigation as well as a primer on matrix calculus.
A key aspect of robotics today is estimating the state (e.g., position and orientation) of a robot, based on noisy sensor data. This book targets students and practitioners of robotics by presenting classical state estimation methods (e.g., the Kalman filter) but also important modern topics such as batch estimation, Bayes filter, sigmapoint and particle filters, robust estimation for outlier rejection, and continuous-time trajectory estimation and its connection to Gaussian-process regression. Since most robots operate in a three-dimensional world, common sensor models (e.g., camera, laser rangefinder) are provided followed by practical advice on how to carry out state estimation for rotational state variables. The book covers robotic applications such as point-cloud alignment, pose-graph relaxation, bundle adjustment, and simultaneous localization and mapping. Highlights of this expanded second edition include a new chapter on variational inference, a new section on inertial navigation, more introductory material on probability, and a primer on matrix calculus.
Get State Estimation for Robotics by Timothy D. Barfoot at the best price and quality guaranteed only at Werezi Africa's largest book ecommerce store. The book was published by Cambridge University Press and it has 530 pages.
Customers Who Bought This Also Bought
Thinking in Systems
KSh 3,050.00
For Everyone Bible Study Guide: Luke
KSh 1,250.00
The Laws of Thought
KSh 2,000.00
Laws of Thought
KSh 3,050.00
Laws of Thought
KSh 4,500.00
Frankenstein and STEAM – Essays for Charles E. Robinson
KSh 22,300.00

Algorithms in Advanced Artificial Intelligence
KSh 30,950.00

Algorithms in Advanced Artificial Intelligence
KSh 9,350.00
Linear Systems Theory
KSh 37,800.00
Fractals and Chaos
KSh 28,450.00
Theories and Models of Urbanization
KSh 26,800.00
Machine Intelligence and Data Analytics for Sustainable Future Smart Cities
KSh 27,000.00