
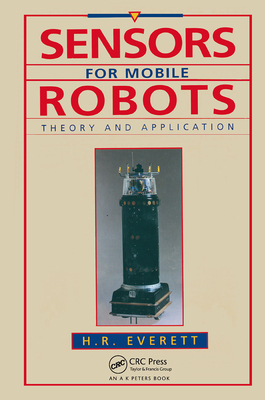
Sensors for Mobile Robots
by
H.R. Everett
Book Details
Format
Paperback / softback
ISBN-10
0367449048
ISBN-13
9780367449049
Publisher
Taylor & Francis Ltd
Imprint
CRC Press
Country of Manufacture
GB
Country of Publication
GB
Publication Date
Dec 2nd, 2019
Print length
544 Pages
Weight
453 grams
KSh 11,700.00
Currently unavailable
0 in stock
Delivery Location
Delivery fee: Select location
Secure
Quality
Fast
This book presents some general background on the sensing needs of a mobile system, followed by sufficient theory of operation and illustrative examples such that the overall result is both informative and of practical use. It examines how non-contact ranging sensors are employed in specific roles.
The author compiles everything a student or experienced developmental engineer needs to know about the supporting technologies associated with the rapidly evolving field of robotics.
From the table of contents: Design Considerations * Dead Reckoning * Odometry Sensors * Doppler and Inertial Navigation * Typical Mobility Configurations * Tactile and Proximity Sensing * Triangulation Ranging * Stereo Disparity * Active Triangulation * Active Stereoscopic * Hermies * Structured Light * Known Target Size * Time of Flight * Phase-Shift Measurement * Frequency Modulation * Interferometry * Range from Focus * Return Signal Intensity * Acoustical Energy * Electromagnetic Energy * Optical Energy * Microwave Radar * Collision Avoidance * Guidepath Following * Position-Location Systems * Ultrasonic and Optical Position-Location Systems * Wall, Doorway, andCeiling Referencing * Application-Specific Mission Sensors
From the table of contents: Design Considerations * Dead Reckoning * Odometry Sensors * Doppler and Inertial Navigation * Typical Mobility Configurations * Tactile and Proximity Sensing * Triangulation Ranging * Stereo Disparity * Active Triangulation * Active Stereoscopic * Hermies * Structured Light * Known Target Size * Time of Flight * Phase-Shift Measurement * Frequency Modulation * Interferometry * Range from Focus * Return Signal Intensity * Acoustical Energy * Electromagnetic Energy * Optical Energy * Microwave Radar * Collision Avoidance * Guidepath Following * Position-Location Systems * Ultrasonic and Optical Position-Location Systems * Wall, Doorway, andCeiling Referencing * Application-Specific Mission Sensors
Get Sensors for Mobile Robots by H.R. Everett at the best price and quality guaranteed only at Werezi Africa's largest book ecommerce store. The book was published by Taylor & Francis Ltd and it has 544 pages.
Customers Who Bought This Also Bought

Theory Of Semiconductor Quantum Dots: Band Structure, Optical Properties And Applications
KSh 26,100.00
Micro Light Emitting Diode
KSh 21,600.00

Hydrogenated Amorphous Silicon
KSh 18,200.00

Topics in Superconductivity Research
KSh 41,600.00
Development of Solar Cells
KSh 28,800.00
High-Energy Ecologically Safe HF/DF Lasers
KSh 37,800.00
Magnetic Monopole Noise
KSh 16,200.00
Circularly Polarized Luminescence of Isolated Small Organic Molecules
KSh 25,200.00
Recent Trends in Materials and Devices
KSh 18,000.00

Semiconductor Advanced Packaging
KSh 19,800.00
Soft Computing in Condition Monitoring and Diagnostics of Electrical and Mechanical Systems
KSh 16,200.00

Progress in the Science of Functional Dyes
KSh 28,800.00
More by H.R. Everett

More in This Genre
Theory Of Semiconductor Quantum Dots: Band Structure, Optical Properties And Applications
KSh 26,100.00
Micro Light Emitting Diode
KSh 21,600.00
Hydrogenated Amorphous Silicon
KSh 18,200.00
Topics in Superconductivity Research
KSh 41,600.00
Development of Solar Cells
KSh 28,800.00
High-Energy Ecologically Safe HF/DF Lasers
KSh 37,800.00
