
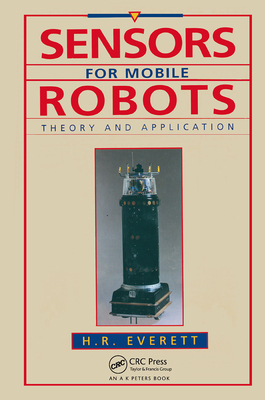
Sensors for Mobile Robots
by
H.R. Everett
Book Details
Format
Hardback
ISBN-10
1568810482
ISBN-13
9781568810485
Publisher
Taylor & Francis Inc
Imprint
A K Peters
Country of Manufacture
GB
Country of Publication
GB
Publication Date
Jul 15th, 1995
Print length
542 Pages
Weight
914 grams
Dimensions
23.50 x 15.40 x 3.50 cms
Product Classification:
Robotics
KSh 30,950.00
Currently unavailable
0 in stock
Delivery Location
Delivery fee: Select location
Secure
Quality
Fast
This book presents some general background on the sensing needs of a mobile system, followed by sufficient theory of operation and illustrative examples such that the overall result is both informative and of practical use. It examines how non-contact ranging sensors are employed in specific roles.
The author compiles everything a student or experienced developmental engineer needs to know about the supporting technologies associated with the rapidly evolving field of robotics.
From the table of contents: Design Considerations * Dead Reckoning * Odometry Sensors * Doppler and Inertial Navigation * Typical Mobility Configurations * Tactile and Proximity Sensing * Triangulation Ranging * Stereo Disparity * Active Triangulation * Active Stereoscopic * Hermies * Structured Light * Known Target Size * Time of Flight * Phase-Shift Measurement * Frequency Modulation * Interferometry * Range from Focus * Return Signal Intensity * Acoustical Energy * Electromagnetic Energy * Optical Energy * Microwave Radar * Collision Avoidance * Guidepath Following * Position-Location Systems * Ultrasonic and Optical Position-Location Systems * Wall, Doorway, andCeiling Referencing * Application-Specific Mission Sensors
From the table of contents: Design Considerations * Dead Reckoning * Odometry Sensors * Doppler and Inertial Navigation * Typical Mobility Configurations * Tactile and Proximity Sensing * Triangulation Ranging * Stereo Disparity * Active Triangulation * Active Stereoscopic * Hermies * Structured Light * Known Target Size * Time of Flight * Phase-Shift Measurement * Frequency Modulation * Interferometry * Range from Focus * Return Signal Intensity * Acoustical Energy * Electromagnetic Energy * Optical Energy * Microwave Radar * Collision Avoidance * Guidepath Following * Position-Location Systems * Ultrasonic and Optical Position-Location Systems * Wall, Doorway, andCeiling Referencing * Application-Specific Mission Sensors
Get Sensors for Mobile Robots by H.R. Everett at the best price and quality guaranteed only at Werezi Africa's largest book ecommerce store. The book was published by Taylor & Francis Inc and it has 542 pages.
Customers Who Bought This Also Bought

Safety-Critical Control with Lyapunov and Barrier Functions
KSh 22,500.00

L'art de l'IA
KSh 3,100.00
Romantic Automata – Exhibitions, Figures, Organisms
KSh 5,750.00
Romantic Automata – Exhibitions, Figures, Organisms
KSh 22,300.00

Intelligent Manufacturing Systems and Industry 5.0
KSh 18,700.00
Learning Robotics, with Robotics, by Robotics – Educational Robotics
KSh 25,000.00
Architectural Intelligence
KSh 23,400.00
Toward Humanoid Robots
KSh 36,000.00

Becoming Strategic with Robotic Process Automation
KSh 5,600.00
Stability, Control and Differential Games
KSh 39,600.00
Human-Friendly Robotics 2019
KSh 32,400.00
Artificial Intelligence and Robotics
KSh 27,000.00
More by H.R. Everett
More in This Genre
Safety-Critical Control with Lyapunov and Barrier Functions
KSh 22,500.00
L'art de l'IA
KSh 3,100.00
Romantic Automata – Exhibitions, Figures, Organisms
KSh 5,750.00
Romantic Automata – Exhibitions, Figures, Organisms
KSh 22,300.00
Intelligent Manufacturing Systems and Industry 5.0
KSh 18,700.00
Learning Robotics, with Robotics, by Robotics – Educational Robotics
KSh 25,000.00